

RCSIM: SLAM & Autonomous Robotics serves as a free expansion within the RCSIM ecosystem, focused on simulation and racing elements tied to radio-controlled vehicles and robotics experimentation on PC. This title emphasizes mapping techniques and navigation testing for RC platforms, allowing users to explore real-world data integration in a controlled software environment.
Gameplay
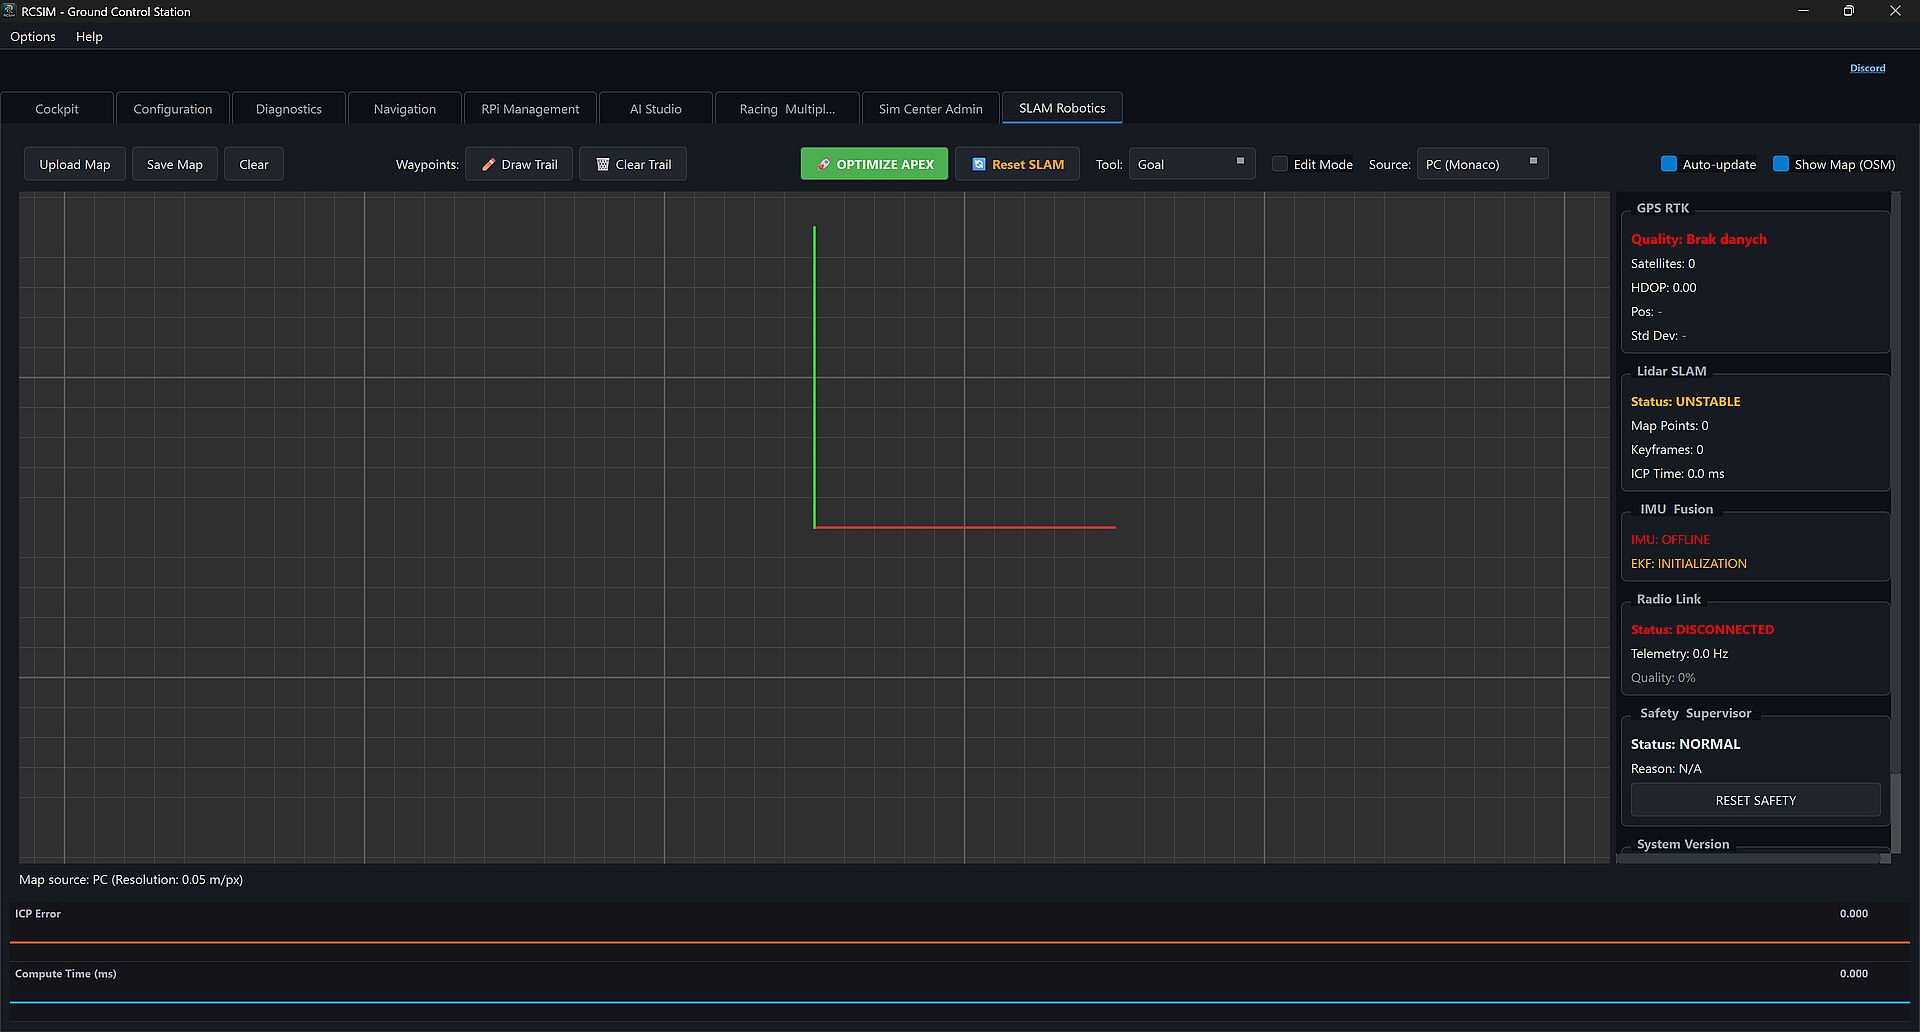
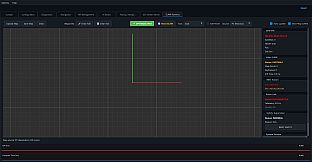
The core loop centers on processing sensor data from compatible RC setups to generate and refine spatial representations. Users interact with live occupancy maps that display environmental layouts alongside vehicle positioning and tracked movement histories. Configuration options for the underlying SLAM engine provide direct control over processing parameters, while performance metrics offer insight into system efficiency during operation.
Additional tools support refinement of generated paths and export of completed maps for further use outside the application. Reset functions enable repeated testing sessions without carrying over prior data. All activity depends on an active connection to the base RCSIM software, along with properly calibrated sensors and a stable data feed from the physical vehicle. Results vary according to hardware quality, setup precision, and surrounding conditions.
Game Modes
No distinct competitive or narrative modes receive explicit confirmation in available details. Instead, the experience revolves around iterative mapping sessions and navigation experiments. Participants configure the SLAM system, monitor real-time indicators, optimize recorded routes, and export outputs as primary activities. These functions align with simulation goals rather than traditional racing circuits or multiplayer matches.
Technical Requirements and Setup
Operation demands the base RCSIM application as a foundation. Compatible sensors and a configured measurement data source must be present for mapping to function. Autonomous features require vehicle-specific tuning to match hardware capabilities. No physical components ship with the software, leaving users responsible for sourcing and integrating their own equipment.
Is It Worth Playing?
This expansion targets individuals already engaged with RC hardware who seek tools for mapping experiments and basic autonomous navigation trials. Its free availability lowers the barrier for those testing SLAM workflows or path planning in conjunction with the main RCSIM platform. Without published user reviews or release metrics at this stage, suitability hinges on personal interest in sensor-driven simulation and robotics configuration rather than broad entertainment value. Those prioritizing visualization of vehicle data and map management will find the focused feature set directly relevant to their projects.